
Bridging the Sim-to-Real Gap: Equipping Humanoid Robots for Industrial Maintenance

By Ahmed Rezika | SimpleWays OU
Published: October 8, 2026
Introduction: Beyond the Industrial Spectacle
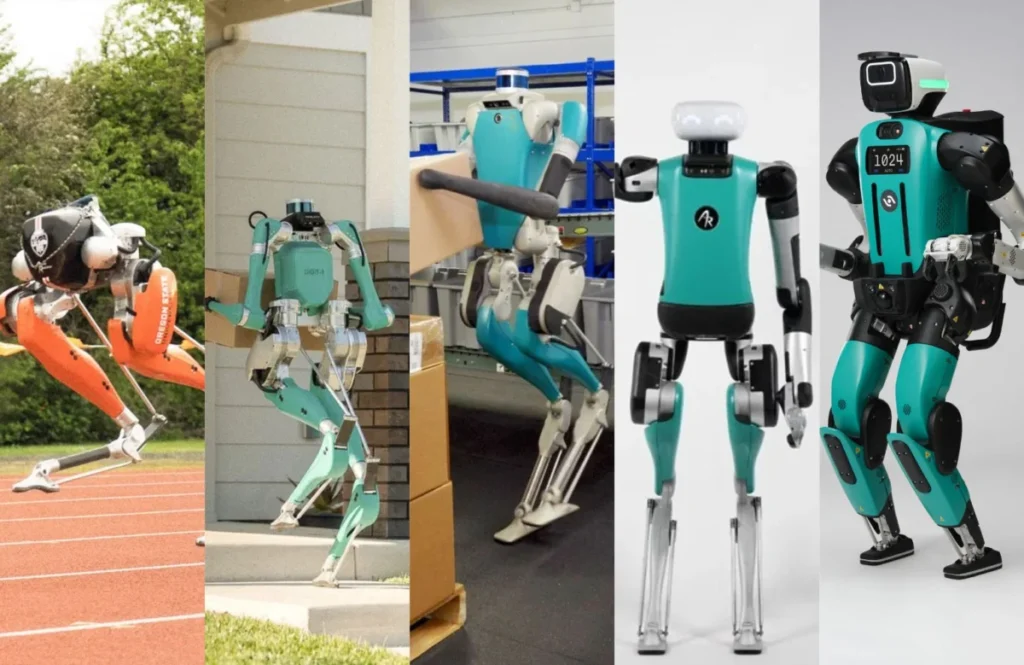
Watching humanoid robots execute high-speed sprints across stadium turf, perform intricate dance routines, or seamlessly recover from sudden balance loss is undeniably fascinating. These public demonstrations capture the imagination, but for maintenance engineers and reliability professionals, they serve a much deeper purpose. They act as public indicators of rapid advancements in mechanical coordination, dynamic balance, and physical interaction.
Yet, as industrial practitioners, we must look beyond the spectacle. Sprinting 100 meters is an extraordinary feat of engineering, but it solves a completely different problem than recognizing a loose terminal connection, positioning a vibration sensor accurately against a bearing housing, or safely opening an unfamiliar equipment enclosure without damaging surrounding infrastructure.
Industrial maintenance demands an entirely different paradigm of operational expectations. We require more than impressive acrobatics and high-speed movement; we need absolute repeatability, reliable physical measurements, measured responses to unpredictable environmental variables, and strict adherence to the safety protocols governing both equipment and plant personnel.
The fundamental question facing industrial automation is no longer whether a humanoid robot can execute a specialized task once under laboratory conditions. Instead, it is whether that robot can perform the task repeatedly, accurately diagnose when an anomaly occurs, and recognize its own operational limits well before intervention becomes critical.
In our previous exploration, Training the Next Maintenance Technician: Can Humanoids Learn Real Industrial Tasks?, we examined how humanoids could acquire procedural knowledge by watching human demonstrations, through remote tele-operation, and by practicing within simulated digital twins. That discussion concluded at the precipice of the "sim-to-real challenge"—the complex difficulty of successfully transferring learned digital competencies into the chaotic, highly variable environment of an operational manufacturing facility.
This second installment picks up precisely at that threshold. We will examine how simulation science, reinforcement learning, and controlled real-world validation are converging to prepare humanoid systems for genuine maintenance workflows. Furthermore, we will analyze why the lessons learned from robotic athletics may ultimately hold more value for plant reliability than the record-breaking benchmarks themselves.
Main Facts: The Reality of Humanoid Robotics on the Shop Floor
The integration of humanoid robotics into industrial environments represents a confluence of advanced artificial intelligence, edge computing, and mechanical engineering. While consumer technology focuses on general utility, the industrial sector has specific baseline requirements for any autonomous agent operating near heavy machinery.
- The Core Objective: The goal of industrial humanoids is not to replicate human form for aesthetic reasons, but to leverage human-centric infrastructure. Factories, stairs, catwalks, control panels, and hand-held tools are built for human dimensions. A humanoid form-factor allows a robot to navigate these spaces without expensive plant redesigns.
- The Training Triad: Moving from a digital concept to a reliable maintenance worker relies on three core pillars: observational learning (imitation), simulated rehearsal (domain randomization), and experiential feedback (reinforcement learning).
- The Verification Standard: Unlike consumer electronics or warehouse logistics bots, maintenance humanoids operate adjacent to high-energy systems, rotating machinery, and energized electrical cabinets. Success is measured not by speed, but by safety, accuracy, and equipment preservation.
Chronology: Milestones in Sim-to-Real and Loco-Manipulation
The pace of robotics research has accelerated dramatically, moving from isolated computer vision experiments to comprehensive loco-manipulation frameworks capable of real-world deployment.
- Late 2025 (The Visionary Breakthrough): Researchers demonstrated foundational sim-to-real reinforcement learning frameworks specifically designed for vision-based dexterous manipulation on humanoid platforms. Systems were trained on complex routines—such as bi-manual box lifting and object handovers—entirely within simulation before being zero-shot transferred to physical hardware using automated real-to-simulation visual tuning.
- Early 2026 (The Rise of VIRAL and Pixel-to-Action): The introduction of frameworks like VIRAL (Visual Sim-to-Real at Scale for Humanoid Loco-Manipulation) allowed researchers to train humanoid movement and manipulation entirely in digital spaces using the Unitree G1 humanoid. By applying aggressive environmental randomization—including variable lighting, camera noise, and structural latency—robots achieved continuous operation in real environments without requiring additional on-premise fine-tuning. Parallel studies successfully transferred pixel-to-action policies for articulated object interaction, such as opening varied industrial doors.
- August 2026 (Online Reinforcement Learning): Academic frameworks such as HARC advanced real-world online reinforcement learning for robotic manipulation, improving success rates across pick-and-place and object-relocation benchmarks.
- October 2026 (Current Industrial Horizon): Maintenance engineers are shifting focus from pure capability testing to task-specific validation, evaluating how these digital frameworks can be safely bounded within plant environments.
Supporting Data and Technical Frameworks
To understand how these systems transition from digital concepts to physical plant tools, we must examine the specific computational mechanisms driving modern robotics.
The Sim-to-Real Gap and Domain Randomization
The sim-to-real gap remains the primary obstacle in deploying artificial intelligence to physical machinery. Minor discrepancies in surface friction, unexpected component wear, ambient lighting changes, and sensor drift can cause an algorithm trained in a pristine virtual world to fail catastrophically on the shop floor.
To counter this, researchers utilize domain randomization. Rather than designing a single, highly idealized digital model of a factory machine, engineers expose the training simulation to wild variations: shifting light angles, distorted textures, unpredictable obstacle layouts, and fluctuating component dimensions.
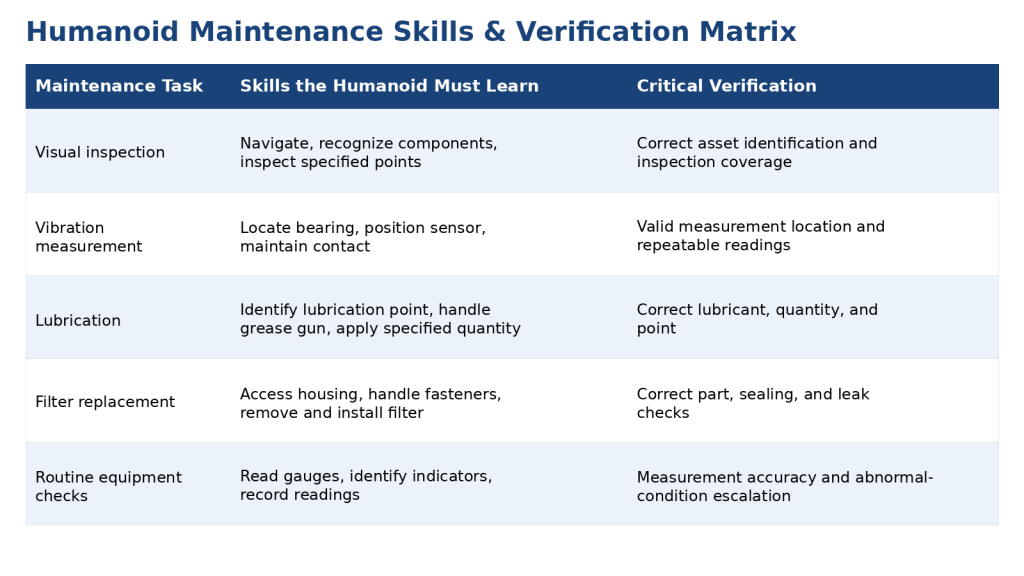
[Human Demonstration]
        ↓
[Simulated Rehearsal (Domain Randomization)]
        ↓
[Reinforcement Learning Feedback Loops]
        ↓
[Controlled Real-Asset Testing & Supervision]
The objective shifts fundamentally:
- Ineffective Goal: "This is the exact coordinate to open this specific access panel."
- Robust Industrial Goal: "This is how you visually identify, approach, manipulate, and verify this class of equipment enclosure under shifting environmental conditions."
Reinforcement Learning: Learning Through Consequence
Beyond imitation, humanoids utilize reinforcement learning (RL), a machine learning methodology inspired by systems like DeepMind’s AlphaZero. Rather than explicitly programming every joint movement, engineers establish a formal reward function outlining successful outcomes. The robot then explores action paths, receiving positive feedback for goal alignment and negative feedback for errors.
Consider the task of pressing a vibration sensor against a rotating bearing housing. A proper reward function would prioritize:
- Maintaining safe spatial clearance from rotating shafts.
- Achieving perpendicular sensor contact with the housing surface.
- Applying optimal, non-destructive contact force.
- Recognizing anomalous readings and halting if instability occurs.
Recent athletic milestones—such as advanced humanoids completing 100-meter dashes in under nine seconds at global robotics competitions—demonstrate the incredible raw agility of modern RL. However, these same events highlight the danger: robots frequently crashed, lost balance under unexpected loads, or failed to stop safely. In an industrial facility, an uncontrolled stop or an unstable heavy lift near an energized turbine is unacceptable. Speed must always be subjugated to safety, precision, and asset protection.
Official Perspectives and Industry Implications
Industrial leaders and maintenance managers are adopting a measured, pragmatic view of humanoid integration. While technology providers market generalized artificial intelligence, plant reliability teams must manage the legal, operational, and financial risks of deploying autonomous hardware.
Managing the Risk Profile
A humanoid robot learning to dance can afford to fall; a humanoid learning to service a high-pressure valve cannot. Consequently, industrial deployment will bypass the "train in simulation and release unsupervised" model. Instead, the implementation pipeline will follow a strict lifecycle:
- Demonstration: Capturing expert human motion and procedural logic.
- Simulation: Running millions of iterations via domain randomization.
- Controlled Practice: Testing policies within isolated, low-risk plant sectors.
- Supervised Execution: Integrating the robot into routine data collection under technician oversight.
- Gradual Autonomy: Expanding operational clearance only after statistical validation of reliability.
Candidate Maintenance Applications
Humanoid utility is best leveraged in tasks requiring human-scale mobility, tool interaction, and navigation through human-centric spaces. Sensible initial applications include:
- Non-Invasive Inspection: Patrolling hazardous or high-temperature zones to collect visual, thermal, and acoustic data using onboard sensors.
- Routine Lubrication: Executing repetitive greasing tasks in areas presenting ergonomic risks or minor chemical hazards to human personnel.
- First-Line Diagnostics: Placing portable diagnostic tools against designated test points across non-critical assets.
Crucially, learned policies will never supersede mandatory safety frameworks. Procedures such as Lockout/Tagout (LOTO), electrical isolation verification, and formal work permits remain absolute human responsibilities. A robot’s primary value is not replacing the expert judgment of a seasoned technician, but augmenting their capabilities by handling repetitive, physically demanding, or hazardous routine data collection.
Conclusion: The Maintenance Colleague We Can Trust
The rapid evolution of humanoid robotics is undeniable. Simulation accelerates algorithmic learning, human demonstrations transfer tacit knowledge, and reinforcement learning refines dynamic execution. Yet, none of these components independently guarantees safe, repeatable maintenance performance.

The future of plant maintenance will not be defined by humanoids that look remarkably human, but by systems whose behavior is rigorously validated, predictable, and transparent. By treating robotics as an extension of standard reliability engineering—focusing on task selection, controlled validation, and strict performance metrics—maintenance departments can successfully transition these systems from laboratory novelties into trusted shop-floor colleagues.
One carefully selected task, one validated skill, and one controlled step at a time, the next era of industrial maintenance is taking shape.
Must-Know Jargon
- Sim-to-Real Gap: The performance discrepancy between a robot operating in a virtual simulation and its behavior in the physical world. Factors like friction variations, sensor noise, and wear cause policies to degrade if not properly addressed.
- Sim-to-Real Transfer: The deployment of control policies developed in digital environments onto physical hardware, followed by rigorous real-world validation.
- Loco-manipulation: The integrated capability of a robot to coordinate whole-body locomotion (moving through space) simultaneously with precise physical object manipulation.
- Domain Randomization: A simulation training strategy that artificially alters environmental parameters—such as lighting, textures, and sensor latency—to prepare algorithms for real-world unpredictability.
- Reinforcement Learning (RL): A machine learning paradigm where an agent learns optimal decision-making by receiving rewards or penalties through trial-and-error interaction with its environment.
- Reward Function: A mathematical formulation that guides an AI agent’s learning process by defining what constitutes successful, safe, and accurate behavior.
- Policy: The learned algorithmic rule mapping a robot’s current sensory observations directly to its subsequent physical actions.
References
- Lin, Toru, et al. "Sim-to-Real Reinforcement Learning for Vision-Based Dexterous Manipulation on Humanoids." Proceedings of The 9th Conference on Robot Learning, PMLR 305:4926-4940, 2025.
- He, Tairan, et al. "Visual Sim-to-Real at Scale for Humanoid Loco-Manipulation." Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026.
- Xue, Haoru, et al. "Opening the Sim-to-Real Door for Humanoid Pixel-to-Action Policy Transfer." Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026.
- Silver, D., et al. "A general reinforcement learning algorithm that masters chess, shogi, and Go through self-play." Science, 362(6419), 1140–1144, 2018.
- Zhang, Y., et al. "Efficient Real-World Online Reinforcement Learning for Robot Manipulation via Centralized Training and Critic Decomposition." alphaXiv, August 2026.
- Rezika, Ahmed. "Training the Next Maintenance Technician: Can Robots Learn Industrial Tasks." MaintenanceWorld.com, September 3, 2026.